Advanced Ship Controller
Engine
For information about engine configuration and setup, see Engine.
Rudder
For information about rudder configuration and setup, see Rudder.
Thruster
For information about thruster configuration and setup, see Thruster.
Settings
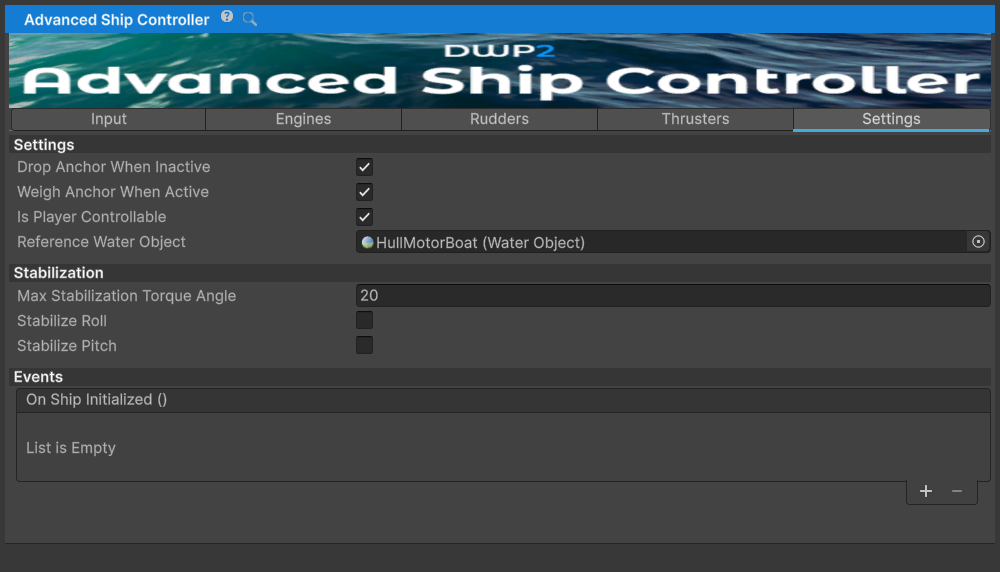
These settings control ship behavior and stability.
Fields
Drop Anchor When Inactive- if there is anAnchorcomponent attached to this ship, the anchor is dropped when the controller is disabled.Weigh Anchor When Active- if there is anAnchorcomponent attached to this ship, the anchor is weighed (raised) when the controller becomes active.Stabilize Roll- if true a torque will be applied to the ship to try and negate any roll.Roll Stabilization Max Torque- maximum torque that will be used for roll stabilization.Stabilize Pitch- if true a torque will be applied to the ship to try and negate any pitch.Pitch Stabilization Max Torque- maximum torque that will be used for pitch stabilization.referenceWaterObject- Reference to the primary WaterObject component used for water height queries. Automatically finds a child WaterObject if not set.
Public Properties and Methods
Properties
SpeedKnots- Current ship speed in knots (1 knot = 1.852 km/h). Calculated from the base Speed property.Anchor- Reference to the ship's Anchor component. Automatically assigned at startup.
Methods
GetPitchAngle()- Returns the ship's pitch angle in degrees. Positive values indicate bow up, negative values indicate bow down.GetRollAngle()- Returns the ship's roll angle in degrees. Positive values indicate starboard side down, negative values indicate port side down.
The 14.3.0 implementation enforces this roll sign. If code written against the 14.2 beta inverted the result to compensate for the former implementation, remove that compensation when upgrading.